

Opening: the immediate operational problem
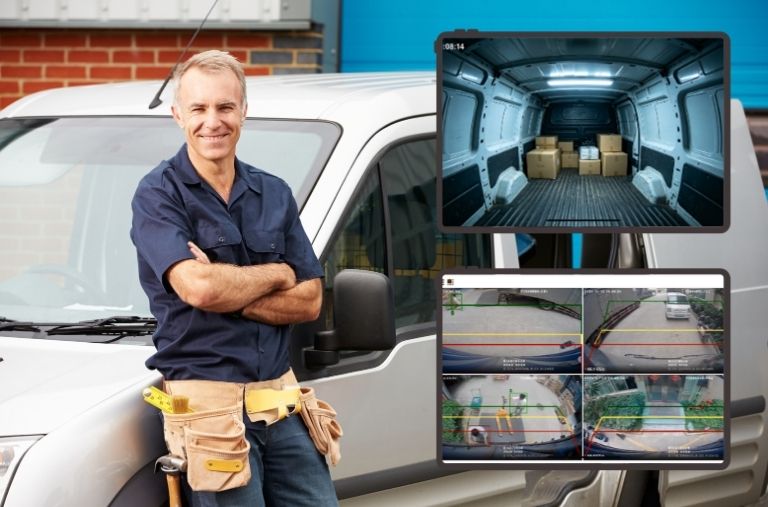
Delivery fleets miss windows, routes overlap, and drivers face avoidable collisions—these issues matter to city operators and logistics architects alike. For small van operators the fix often begins with focused tooling such as van fleet management and accurate gps tracking for delivery vehicles, especially where dense traffic complicates last-mile timing, as seen in urban last-mile operations in London. The gap isn’t lack of devices; it’s unclear integration boundaries between dispatch, live telemetry, and safety systems.

The problem mapped: what breaks at scale
Operators report three recurring failures: delayed routing decisions, telemetry blind spots, and safety alerts that arrive too late. These failures compound: a late dispatch causes tight schedules, drivers speed to recover time, and collision-avoidance alerts become noise instead of precise interventions. Treat the stack as a single system rather than isolated products—each layer must expose clear interfaces and service-level expectations.
Root causes to fix first
Poor outcomes trace to concrete technical issues: intermittent GNSS accuracy handling, asynchronous message flows between dispatch and vehicle agents, and monolithic control panels that obscure latency. Solve the weakest link. Prioritize telemetry consistency, deterministic routing behavior, and event prioritization so safety messages always preempt noncritical updates.
Architectural principles (Cloud Architect English)
Design choices that scale:- Separate concerns: device telemetry, route orchestration, and collision-avoidance should live in distinct services with well-documented APIs.- Use edge filtering: process high-frequency sensor data on the vehicle to reduce noise sent to the cloud.- Guarantee priorities: employ a QoS model so safety events take precedence over location pings.- Plan for graceful degradation: when connectivity drops, ensure local routing and safety logic continue to operate.
Practical integration steps
Follow this sequence to reduce risk:1) Baseline telemetry quality: define acceptable GNSS error margins and standardize frequency. 2) Implement an event bus between dispatch and vehicle agents; enforce schema and timestamps. 3) Add an edge module for collision-avoidance that produces concise actionable events rather than raw sensor dumps. 4) Validate behaviors under load with staged field tests. Document APIs and failure modes so operations know what to expect.
Common pitfalls and how to avoid them
Avoid these mistakes:- Treating GPS data as perfectly accurate—always fuse with vehicle speed and heading. – Centralizing all decisions in the cloud—local autonomy matters when latency spikes. – Ignoring human factors—present alerts that drivers can action in under two seconds. – Skipping end-to-end tests in real traffic conditions.
Comparing viable alternatives
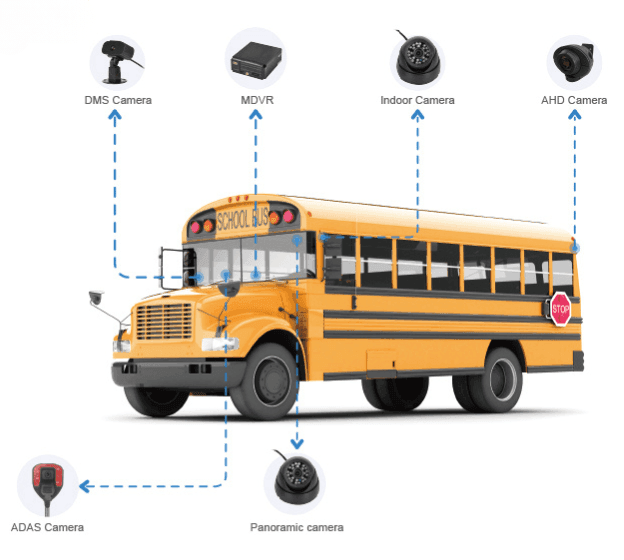
When choosing components, weigh trade-offs: embedded collision modules reduce latency but add cost; cloud-based routing scales but requires resilient connectivity; lightweight telematics lower data costs but offer coarser diagnostics. Match choices to operational risk and workload: high-frequency urban routes demand stronger edge logic; rural runs tolerate more cloud processing.
Synthesis and operational value
A problem-driven approach forces clear interfaces, predictable behaviors, and targeted testing—this reduces late deliveries and prevents avoidable collisions while keeping the system scalable. For teams that need a pragmatic, integrated solution rather than isolated tools, consider platforms that combine dispatch orchestration, robust telemetry, and prioritized safety events—solutions like BSJ fit into that architecture without replacing operator judgment or local controls.